Point Cloud to COPC
The code below uses the Toolbox SDK, which you can install with pip install toolbox-sdk.
Additional Python examples: using SDK, using Requests. If you prefer other programming language or need full API reference, check out Toolbox OpenAPI as well.
Docs
Converts point clouds files to Cloud Optimized Point Cloud (COPC).
COPC stores point data organized in a clustered octree. It reduces data transfer time, improves performance, and makes it easier to work with large datasets on cloud platforms.
Inputs:
Input point cloud file in any PDAL-supported format (LAS, LAZ, PLY, PCD, PTS, PTX, BPF);
Source CRS - Set if missing from input file metadata. EPSG code, for example,
EPSG:4326;Output CRS. Set to reproject the result. EPSG code, for example,
EPSG:4326;Coordinate precision - for example.
0.01. Leave empty to use auto mode;-
Attributes:
All (all) - use all attributes;
Standard (standard) - use standard COPC attributes subset.
Outputs:
Cloud Optimized Point Cloud in LAZ format.
Example:
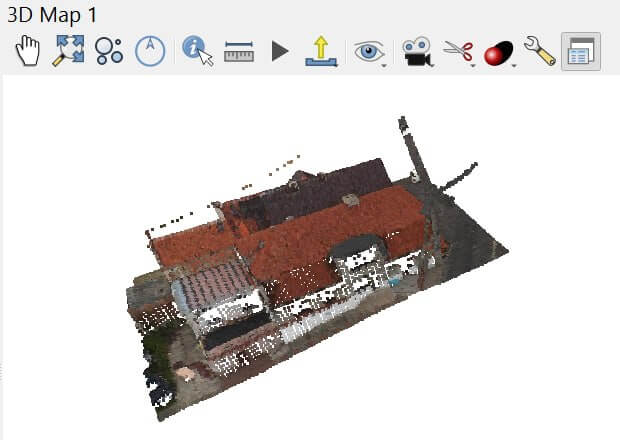
Point cloud
Try the tool in action
Click on the Demo button above the tool form. The fields are filled in with demo values.
Click on the Run button.